Print settings
- Material
- PLA Basic
- Layer height
- 0.12 mm
- Wall loops
- 4
 WUDI Hardware
← Project page
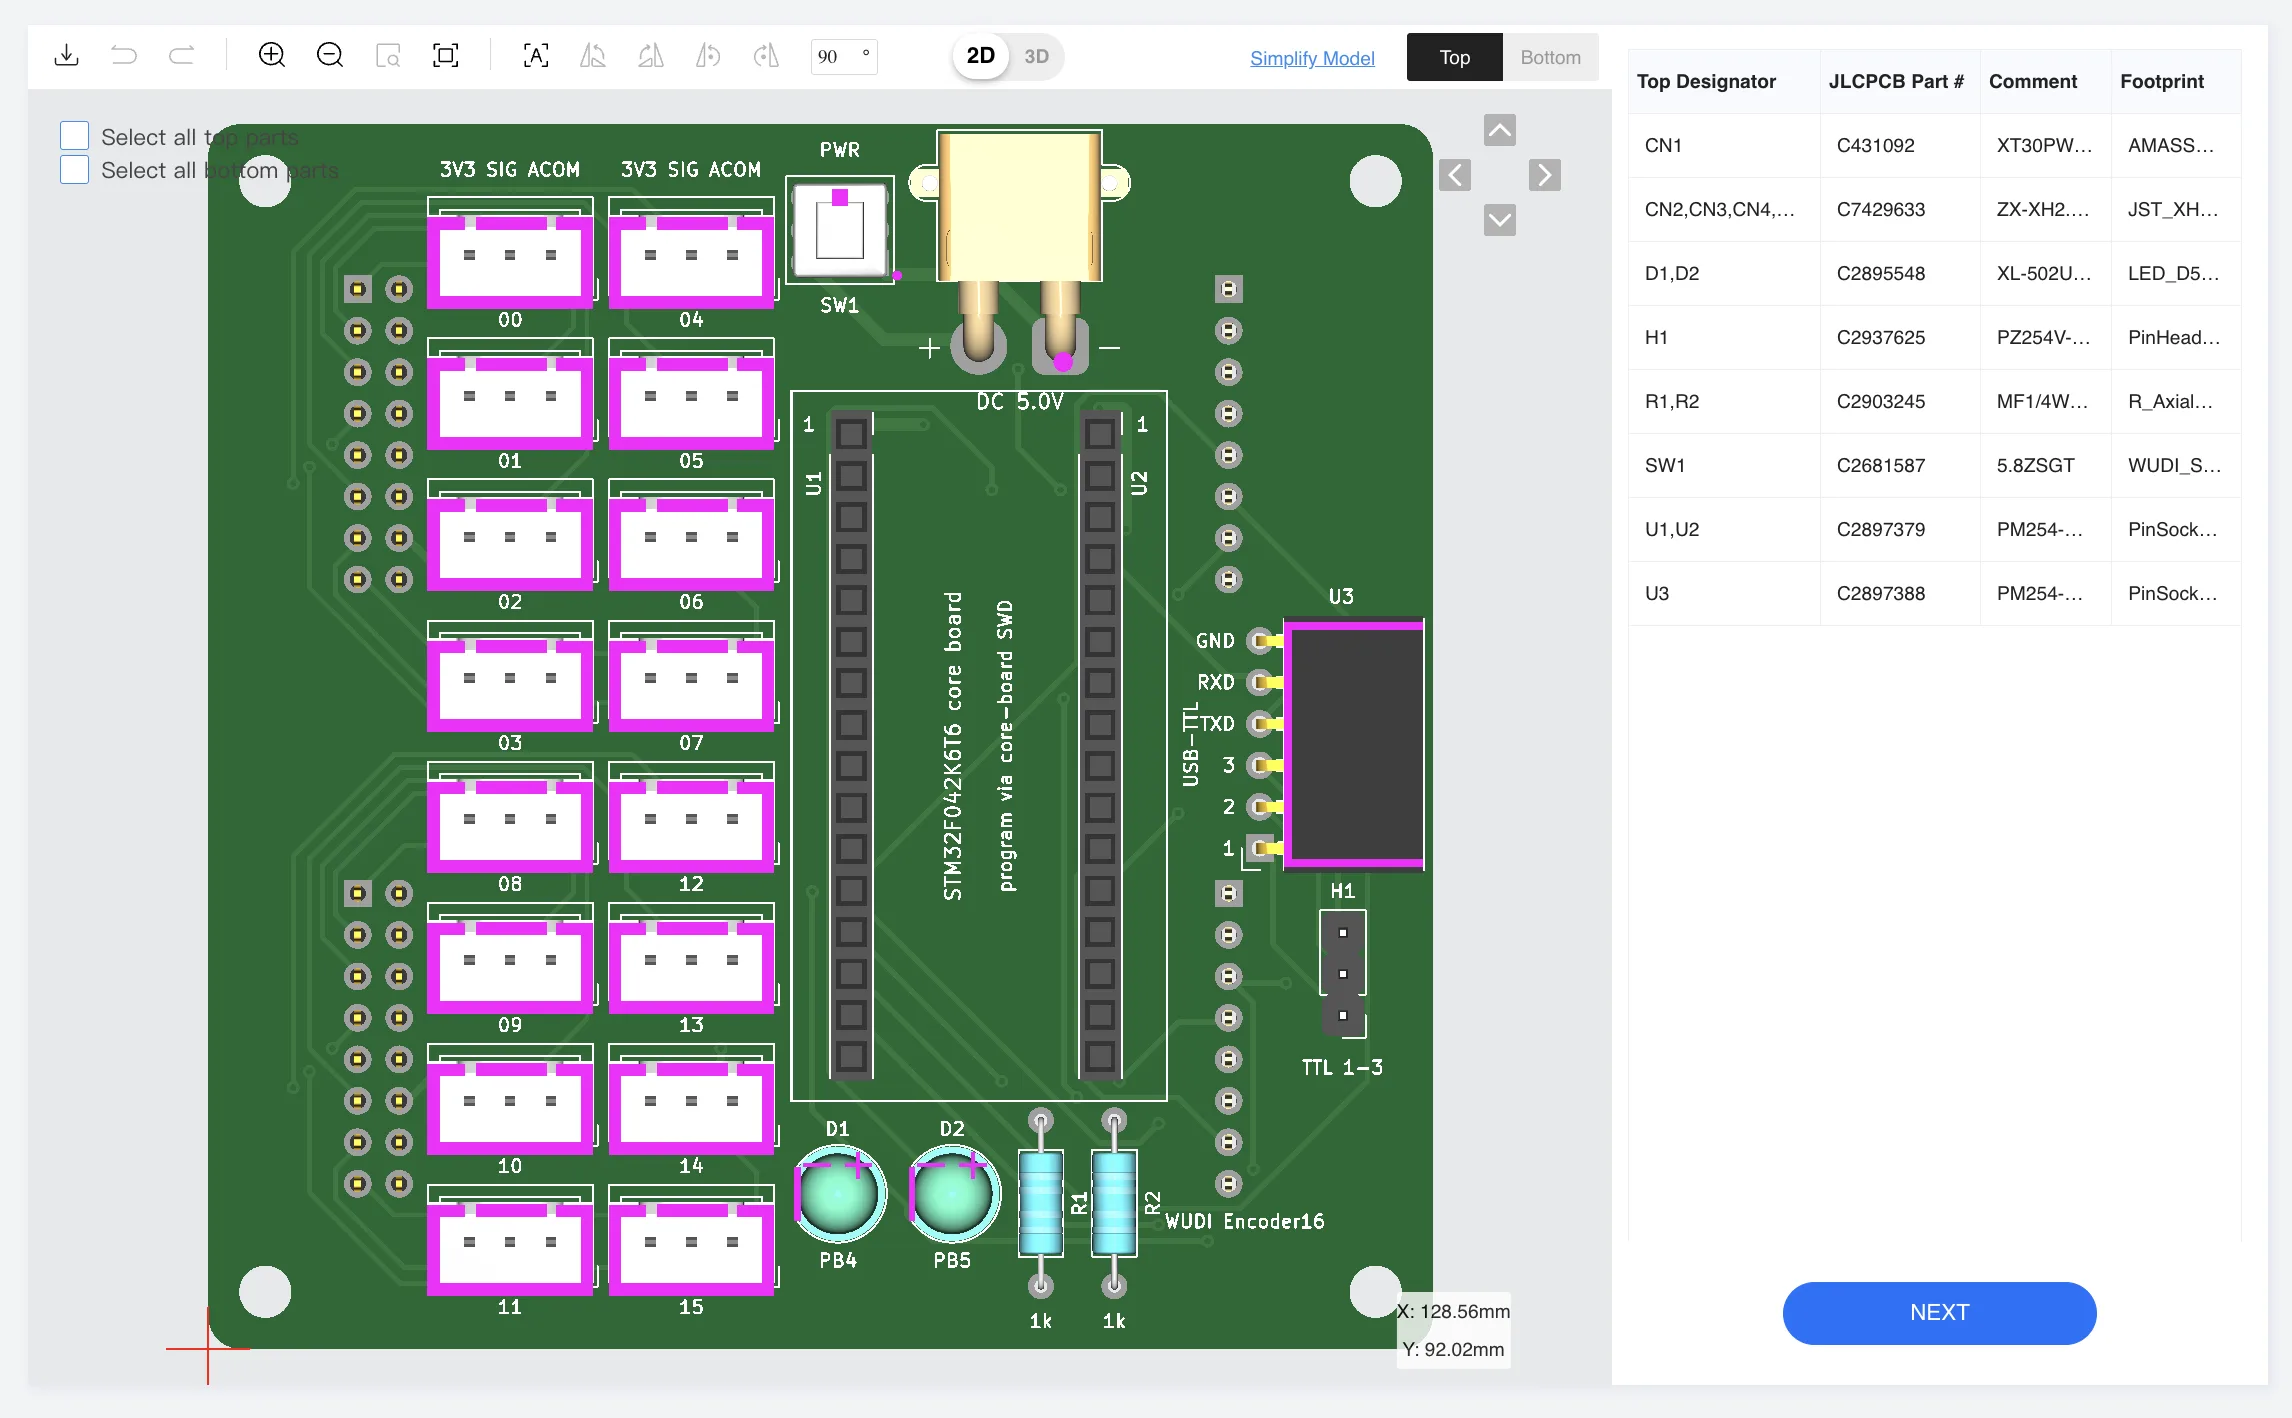
Based on the open-source DexUMI electronics design [1], our 75 × 75 mm mainboard keeps the same STM32F042K6T6 and dual-ADS1256 architecture, exposes all 16 encoder channels, and removes unused circuitry.
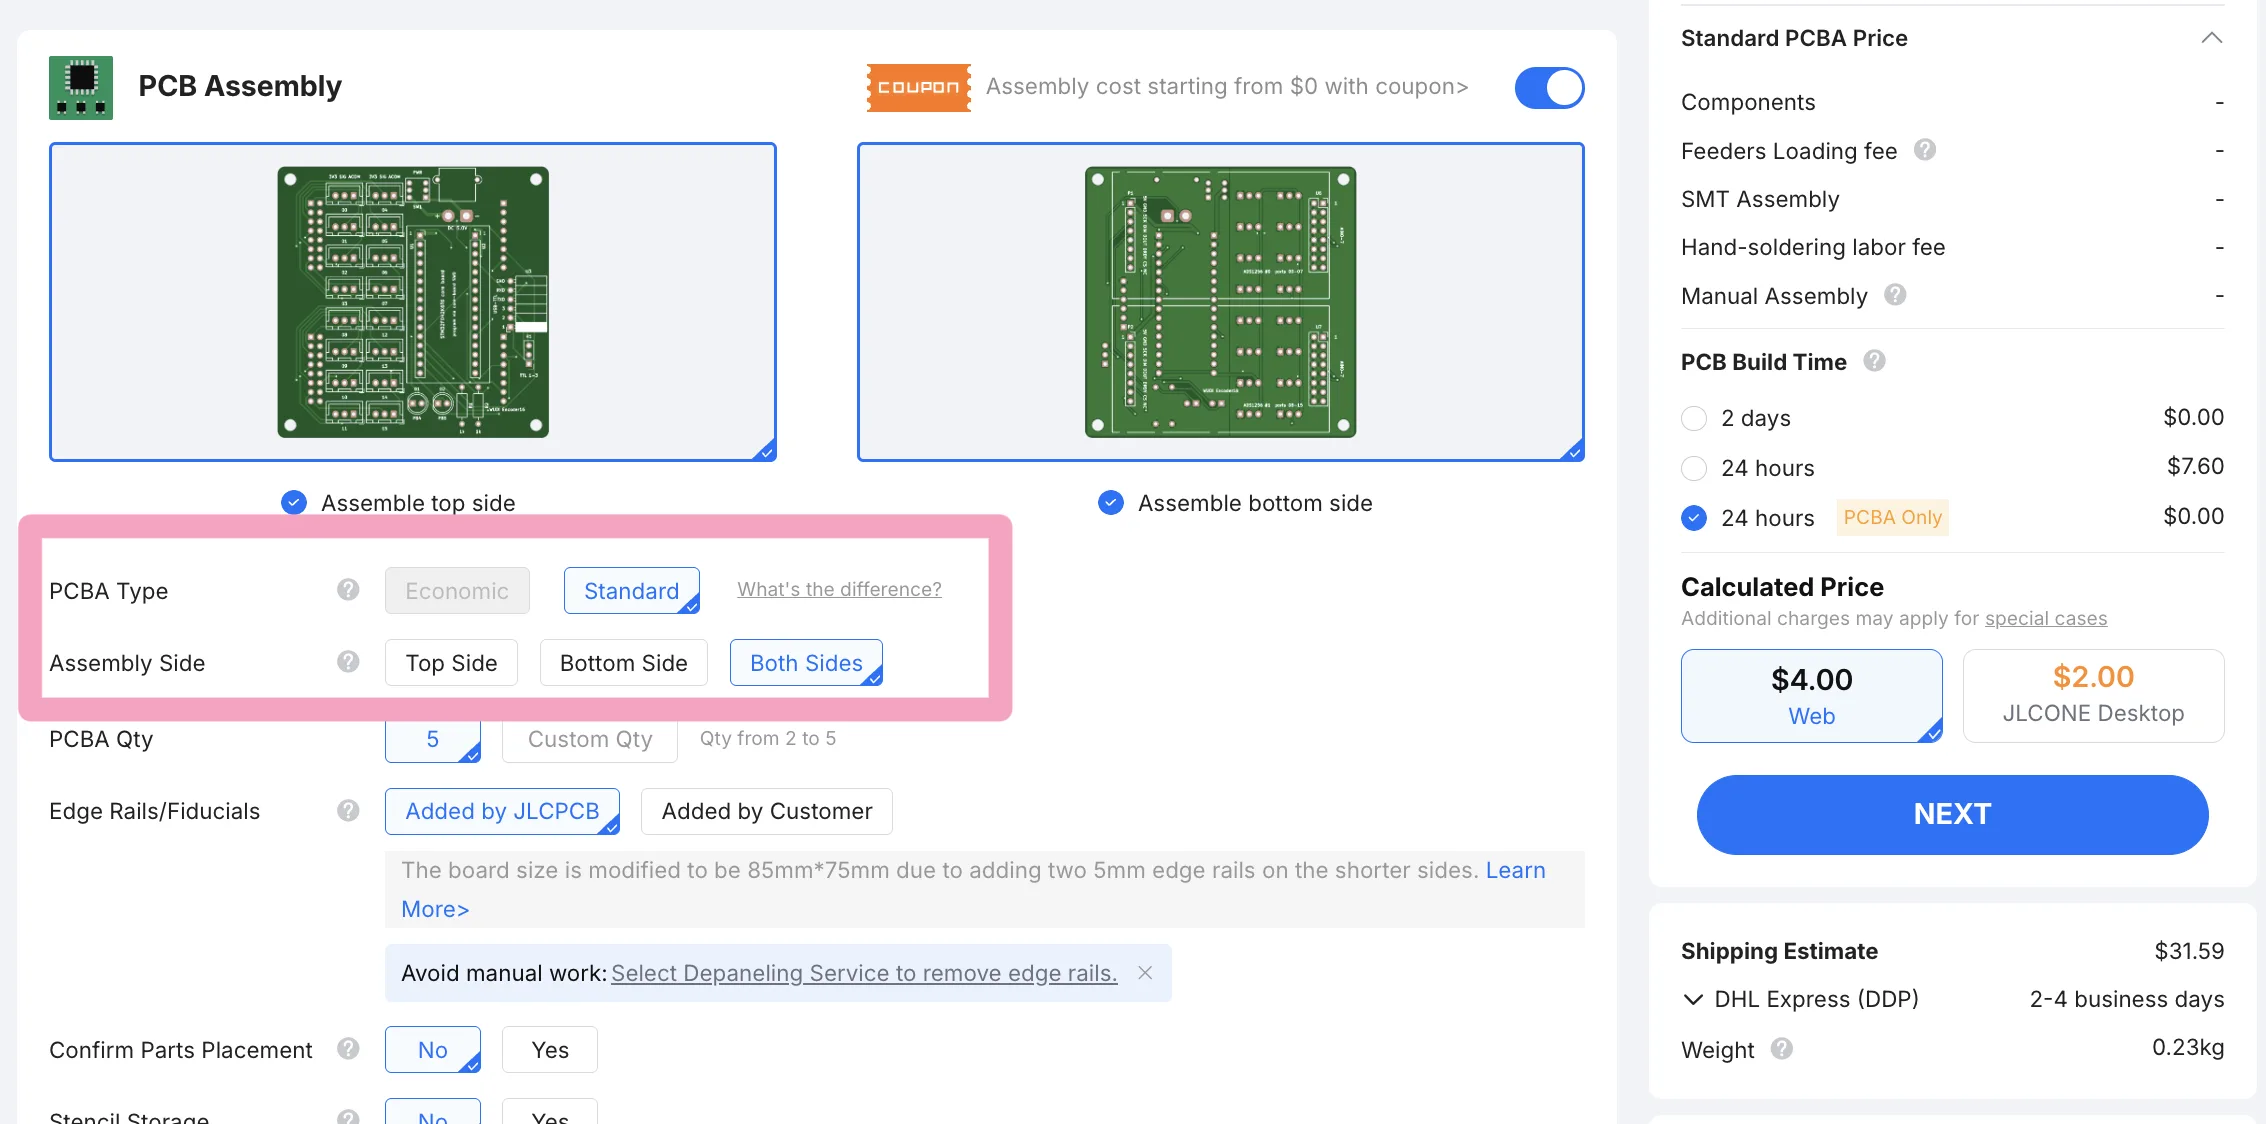
Gerber.zip.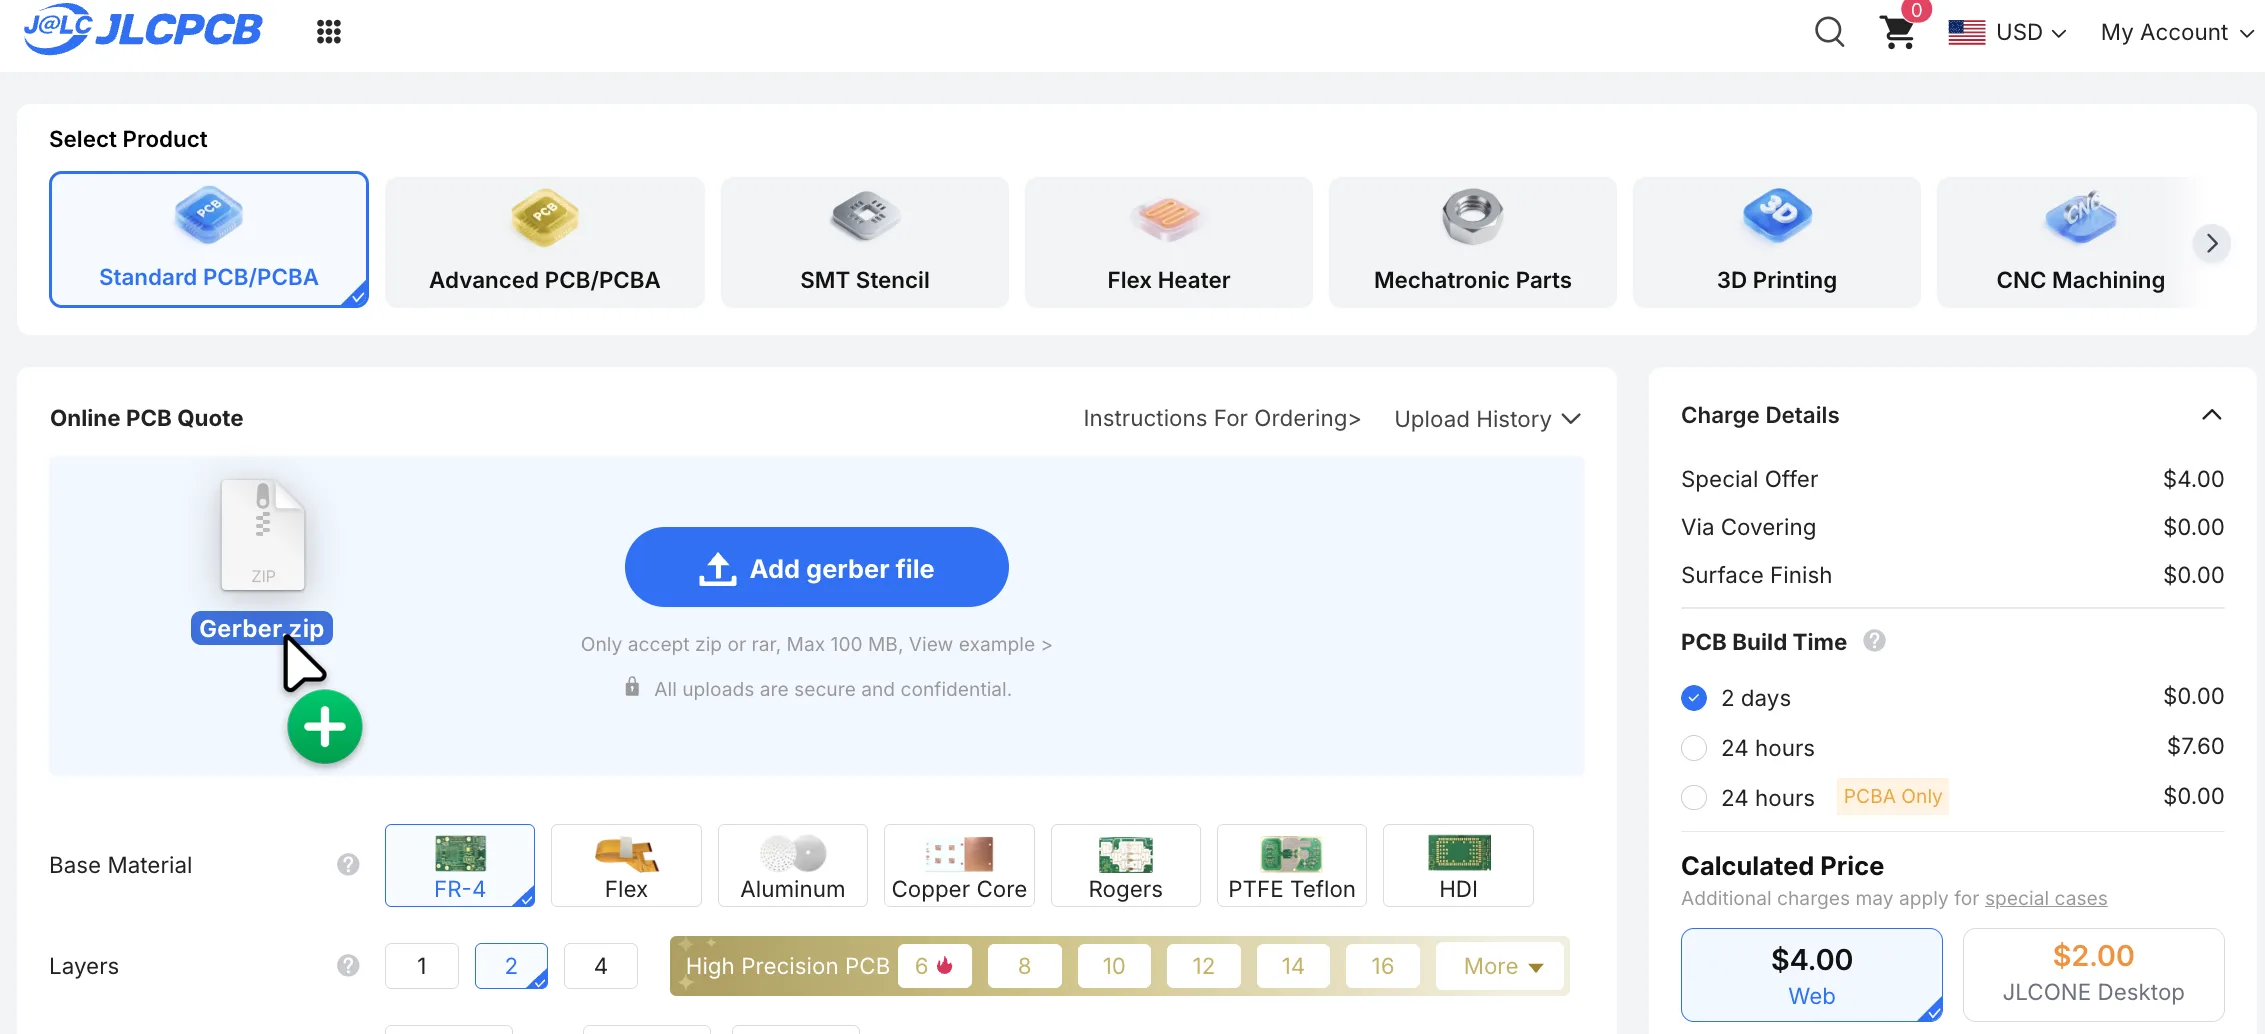
BOM.csv, then add CPL.csv for placement.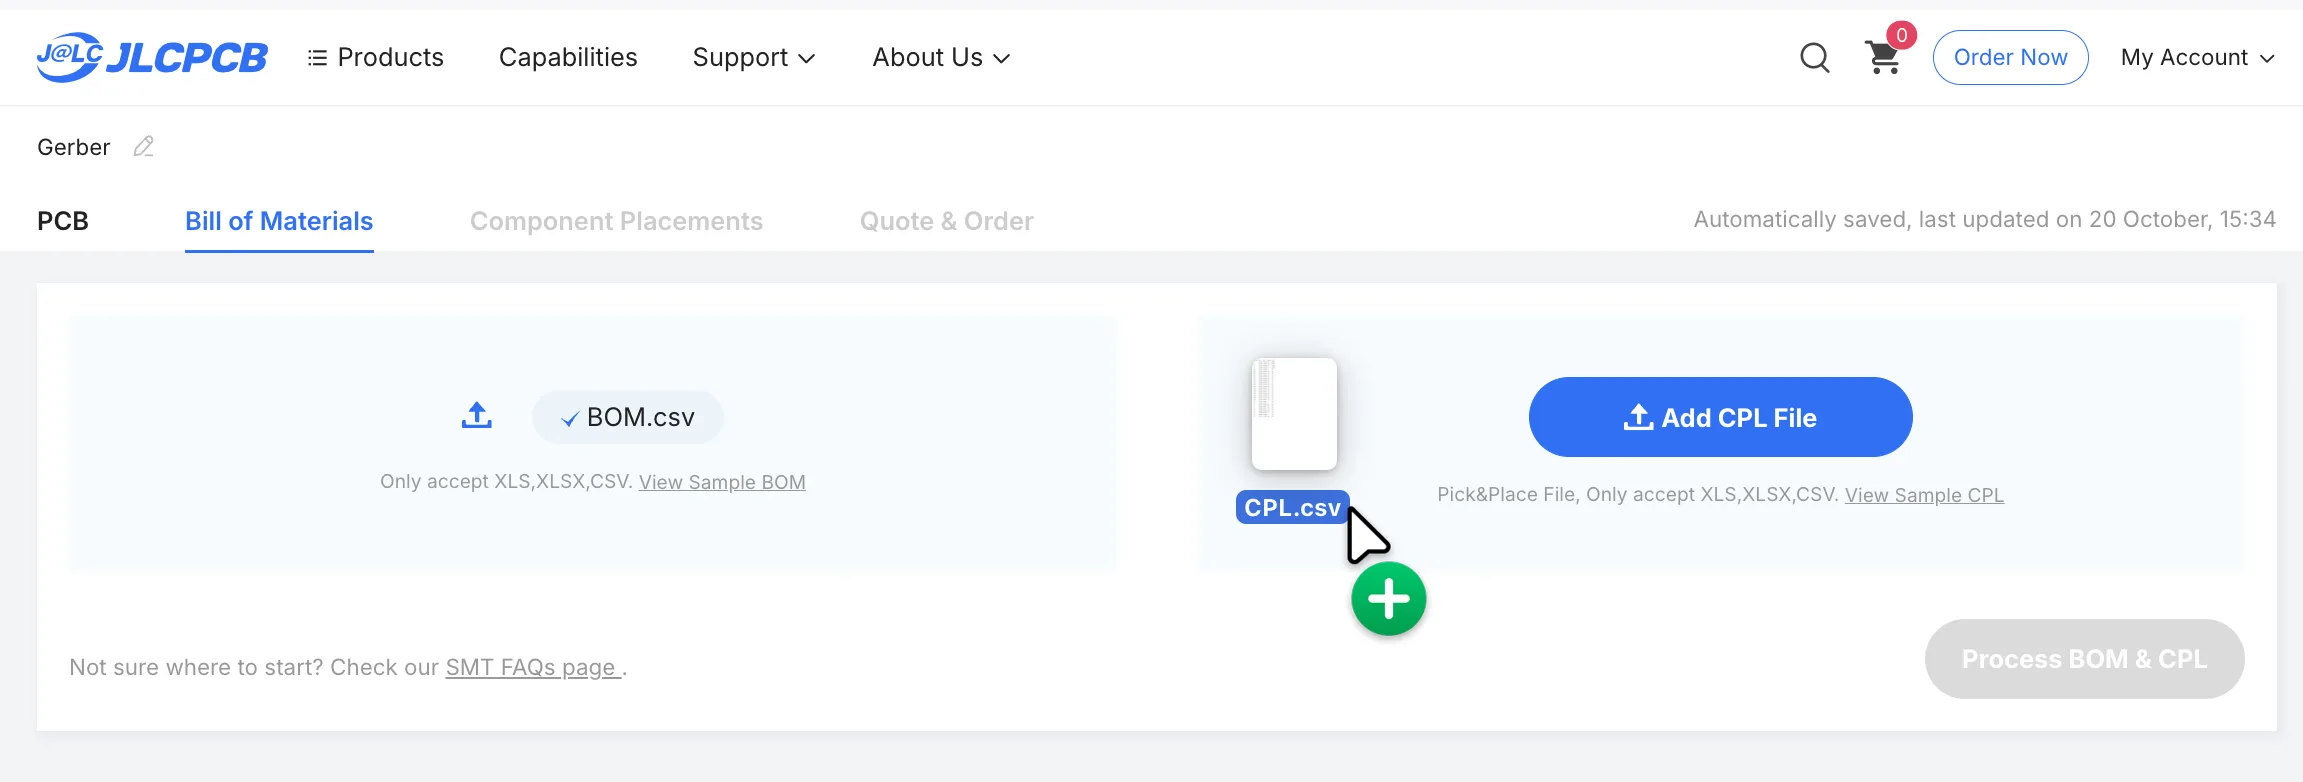
| Part | Qty | Use / note |
|---|---|---|
| Mechanical hardware | ||
| PLA Basic filament ↗ | 1 spool | WUDI exoskeleton printed parts |
| PLA-CF filament ↗ | 1 spool | Structural printed parts |
| M3 assorted screw and nut kit ↗ | 1 box | Multiple lengths for finger pivots and assembly |
| M3 × 10 mm stainless-steel shoulder screw, 4 mm shoulder ↗ | 20 | Finger pivots |
| M3 stainless-steel lock nuts ↗ | 1 pack | Secure the finger pivots |
| M3 × 10 mm Chicago screws ↗ | 1 pack (24 sets) | Binding posts for linkage assembly |
| M3 external E-clips ↗ | 1 pack (200) | Retain 3 mm shafts and pins |
| M3 × 6 mm steel shim washer set ↗ | 1 set (48) | 0.1 / 0.2 / 0.3 / 0.5 mm linkage spacing |
| 3 × 15 mm dowel pins ↗ | 1 pack (100) | Linkage pivot pins |
| 3 × 18 mm dowel pins ↗ | 1 pack (100) | Linkage pivot pins |
| 3 × 20 mm dowel pins ↗ | 1 pack (100) | Linkage pivot pins |
| 3 × 35 mm dowel pins ↗ | 1 pack (100) | Linkage pivot pins |
| 3 × 40 mm dowel pins ↗ | 1 pack (50) | Long linkage pivot pins |
| Galvanized-steel connector plates, 2.36 × 0.63 in ↗ | 1 pack (20) | Flat metal joining plates |
| 3M TB641 gripping material ↗ | 1.5 ft | Grip surface |
| Electronics | ||
| WUDI Encoder16 mainboard ↑ | 1 | Order the assembled board in Step 01 |
| RDC506018A encoder ↗ | 16 | Joint sensing |
| XH 2.54 mm 3-pin wire, 50 cm ↗ | 16 | Encoder leads |
| JST XH2.54 3-pin male/female cable sets ↗ | 2 packs (20 sets each) | 15 cm, 26 AWG connector leads |
| 2.54 mm 40-pin male breakaway headers ↗ | 1 pack (20 strips) | PCB and module connections |
| STM32F042K6T6 core board ↗ | 1 | Same MCU module used by DexUMI |
| ADS1256 module ↗ | 2 | 16 analog input channels total |
| USB-to-TTL module, 3.3 V logic ↗ | 1 | Runtime serial connection to the PC |
| ST-Link V2 programmer ↗ | 1 | Firmware flashing over SWD |
| 5.0 V / 1.0 A DC power supply ↗ | 1 | Mainboard power |
| USB 2.0 male to 2-pin bare-wire power cable, 50 cm ↗ | 1 pack (2 cables) | 24 AWG USB power lead |
| XT30 male/female connector set ↗ | 1 set | Power input and mating lead |
| Dupont jumper wire kit ↗ | 1 box | Programming and bench connections |
| Camera and other items | ||
| Intel RealSense D405 ↗ | 1 | Wrist-mounted RGB-D camera |
| Lucas Oil 10533 White Lithium Grease ↗ | 1 | Lubricate moving mechanical interfaces |
| Scotch Super Glue Liquid, AD114 ↗ | 1 | Small-part assembly |
| Tools make life much easier | ||
| Dremel 8240 cordless rotary tool ↗ | 1 | Drilling, trimming, deburring, and small-part finishing |
| Wera 950/9 Hex-Plus metric key set ↗ | 1 set | Color-coded metric hex keys make repeated assembly easier |
| Xiaomi Electric Precision Screwdriver ↗ | 1 set | Fast, low-torque assembly with a compact precision bit set |
The STEP and STL files contain the exoskeleton CAD. Use the STL for printing and the STEP model for CAD reference or modification.
WUDI keeps the same STM32F042K6T6 and dual-ADS1256 modules as DexUMI; only the carrier mainboard is replaced.
sudo apt-get install openocd.WUDI_Encoder16.hex in the current directory, and run:openocd -f interface/stlink-v2.cfg \
-f target/stm32f0x.cfg \
-c "program WUDI_Encoder16.hex verify reset exit"Do not use a 5 V UART signal. Disconnect ST-Link after flashing unless the shared-ground debug setup has been reviewed.
BIN SHA-2560ddb9dcba86dc33f97ae636f923d219fb492d62f53ba763dddd8e0c77025e3d9