Bio Robot
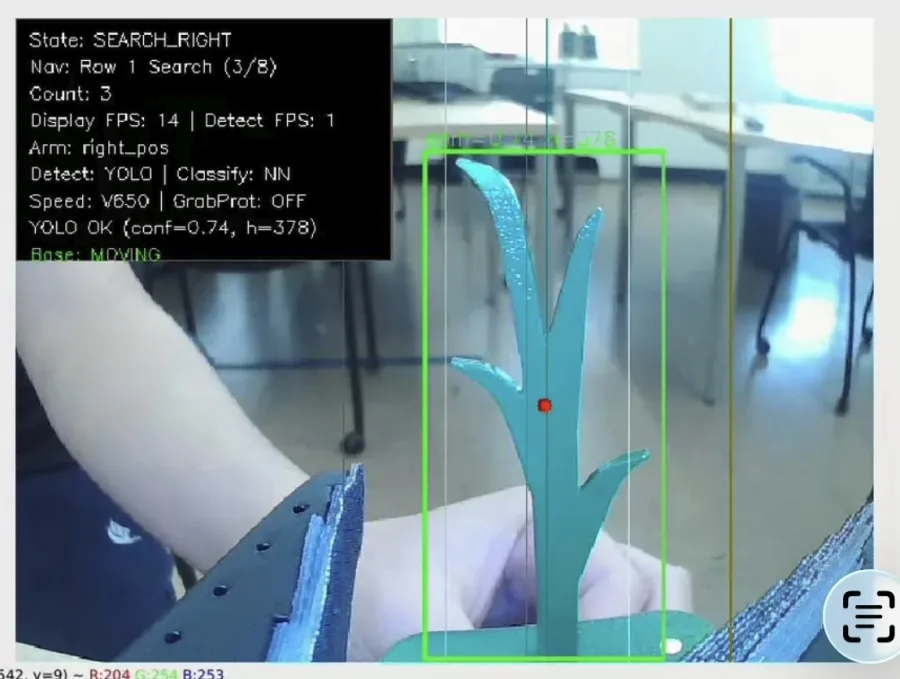
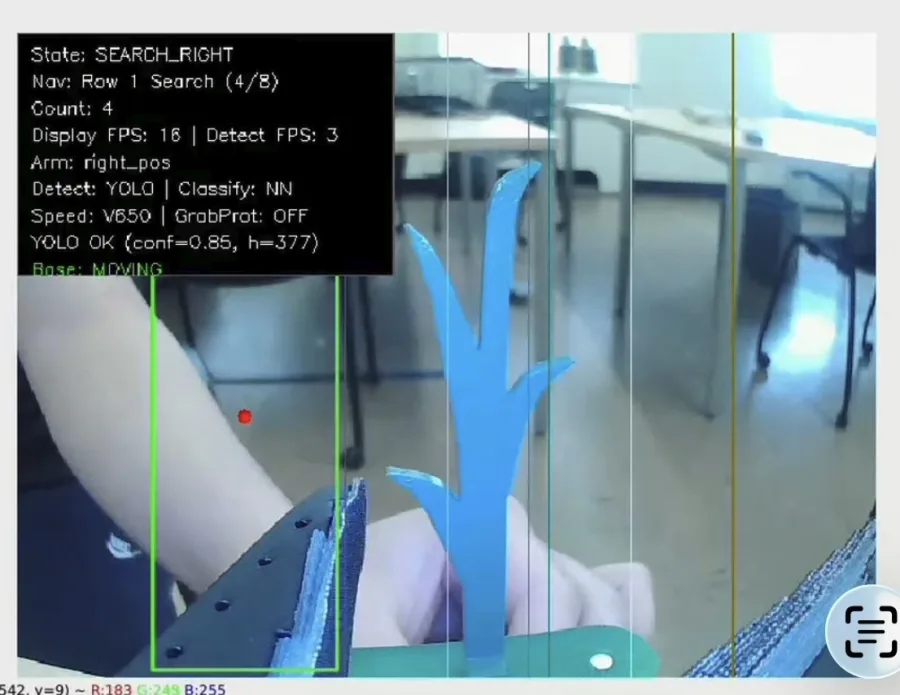
Perception in the loop
An Innomaker camera with LED-assisted illumination supplies images to YOLOv8 Nano for plant detection and MobileNetV3 for classification of healthy and unhealthy crops.
A Raspberry Pi handles camera input, object detection, classification, and arm control. An Arduino manages motor control, line following, and sensor feedback.
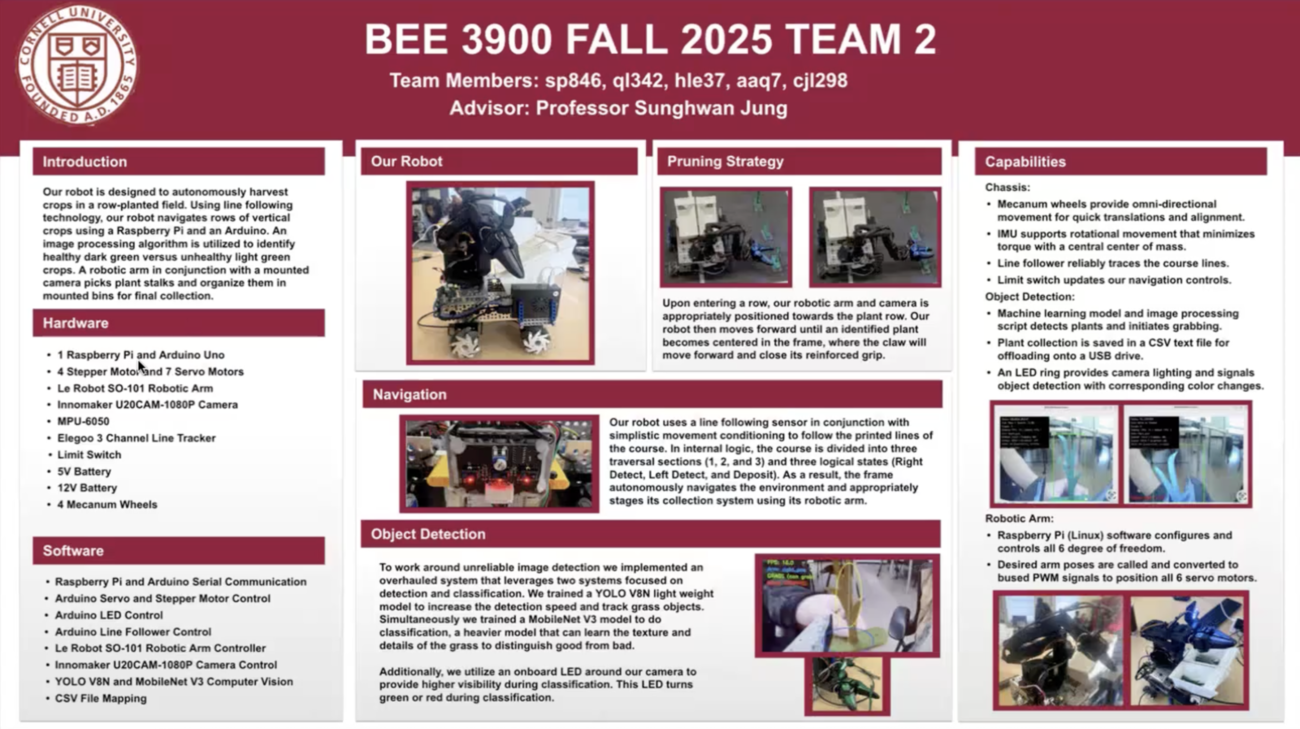
See, navigate, harvest
An autonomous crop-harvesting robot that follows planted rows, detects crops, classifies plant condition, and uses an SO-101 robotic arm for pruning or collection.
Four mecanum wheels provide omnidirectional motion for alignment with crops. A three-channel line tracker, IMU, and limit switches support navigation, while a Le Robot SO-101 arm positions the claw for manipulation.